Terrain-adaptive exoskeleton
I built a lower-extremity exoskeleton to explore terrain-aware gait assistance.
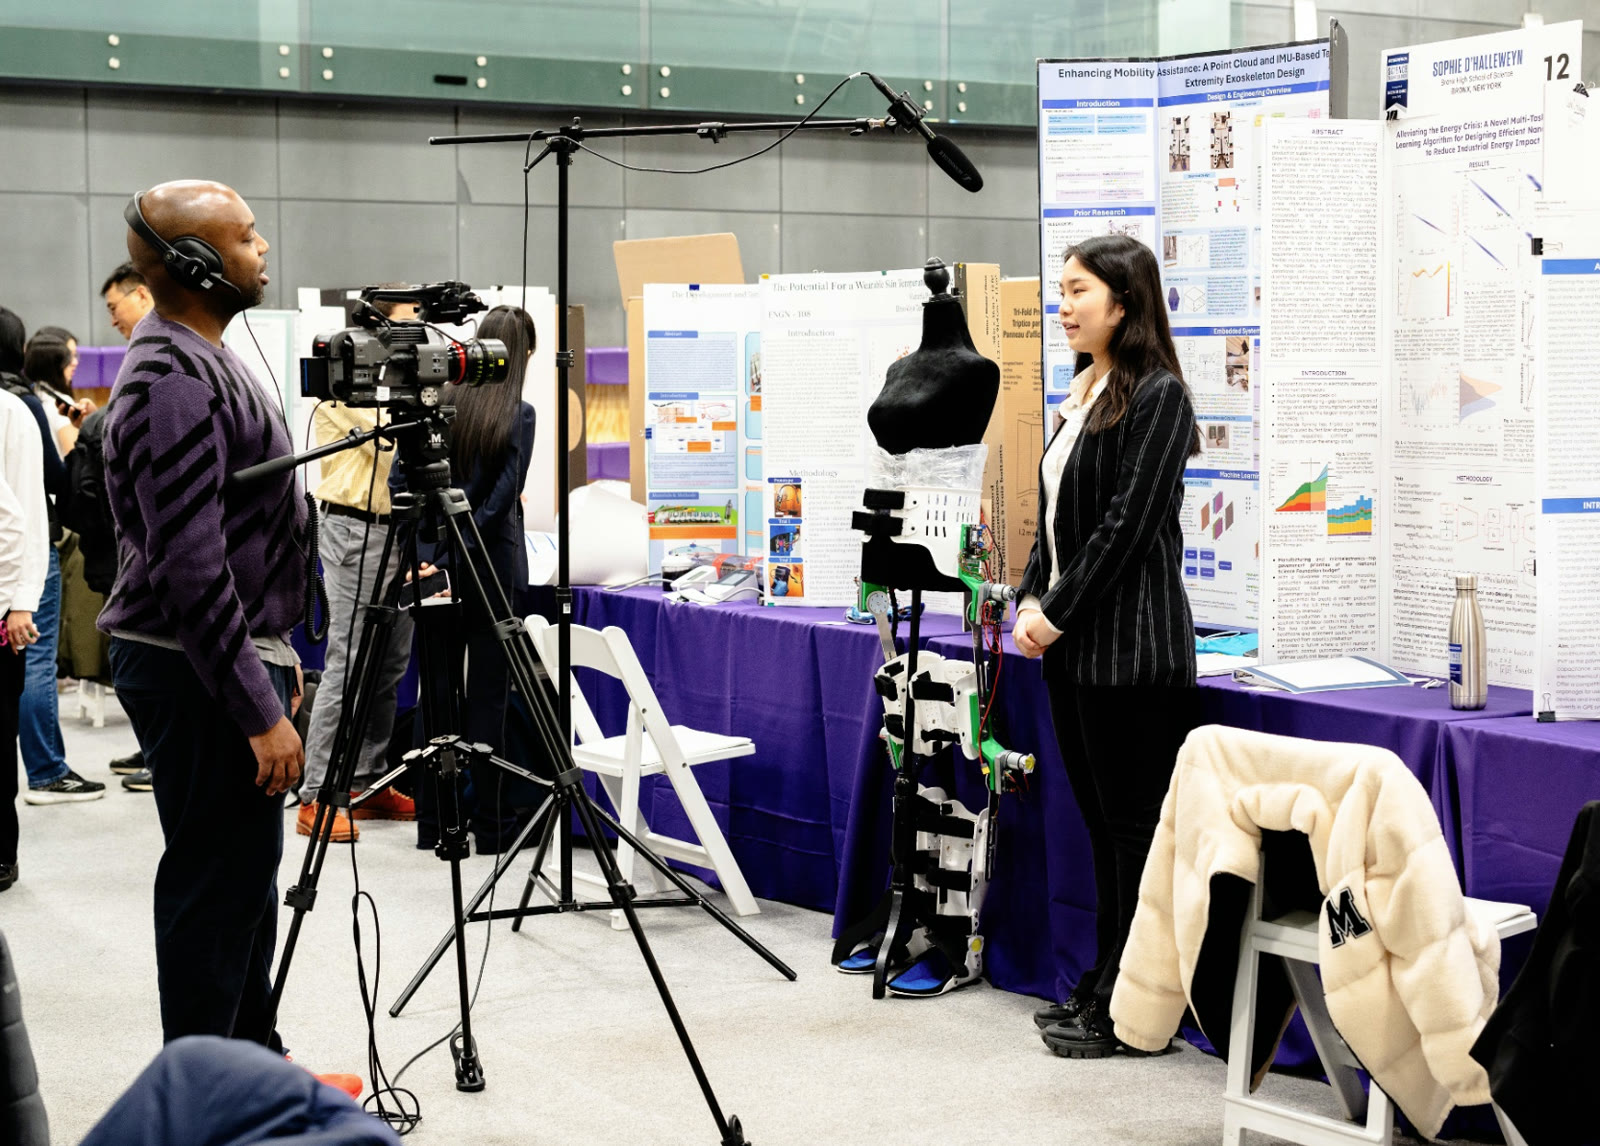
The question
How can an exoskeleton adapt its gait assistance to the terrain ahead?
I designed and built a lower-extremity exoskeleton combining IMU and RGB-D sensor fusion, real-time terrain classification using PointNet++, gait prediction models, and high-torque servo control.
Prototype demo
40-second demo of the supported, bench-mounted prototype.
System overview
01 / Sense
IMU + RGB-D inputs capture motion and the surrounding terrain.
02 / Interpret
PointNet++ classifies terrain; gait prediction models inform the control system.
03 / Actuate
High-torque servos execute the assisted leg movements.
Architecture overview.